
Atlas Humanoid Gets a Four-Finger, 13-Joint Hand Built for Tool Work
Boston Dynamics has unveiled a new hand for its Atlas humanoid robot. The hand has four fingers and 13 degrees of freedom, up from seven on the previous version. One […]
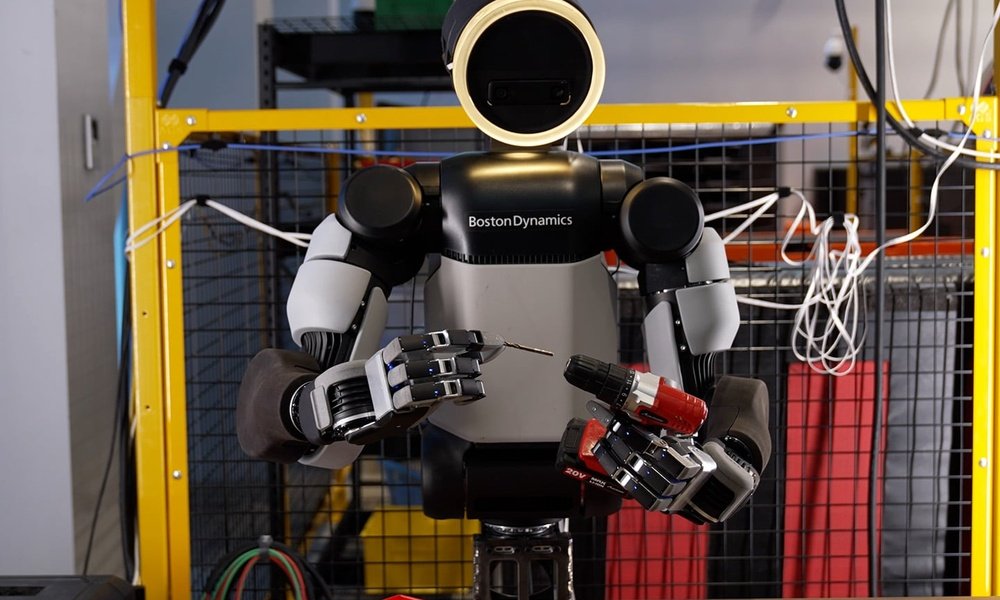
Boston Dynamics has unveiled a new hand for its Atlas humanoid robot. The hand has four fingers and 13 degrees of freedom, up from seven on the previous version. One common actuator design drives every joint, and the actuators are sealed inside the hand with no wiring running over the joints.
Where the earlier hand mainly held objects, the new one can work with them while gripping. A four-joint thumb and three-joint fingers support pinch and tripod grips, turning parts within the hand, and recovering a slipping hold. Atlas can also operate triggered tools, including drills, grinders, nail guns and welding torches.
Existing industrial automation depends on tightly controlled part presentation and grippers made for specific parts. The company argues that dexterous hands are needed to pick parts from shelves, crates, slots and piles, and to take on manual jobs such as tool use, cable handling and bin picking. The hand is also designed for mass manufacturing, low cost and reliable repair.
The team left out a fifth finger, judging that three extra actuators would add cost, bulk and failure points. Backdrivable actuators and controls that offset cogging and friction let the hand be simulated closely for reinforcement learning, but transfer from simulation to hardware is still at the initial-results stage.
Image Source – Boston Dynamics